FUNCTIONAL MODULE / COMPONENT INTERFACES
Handling & actuator interfaces
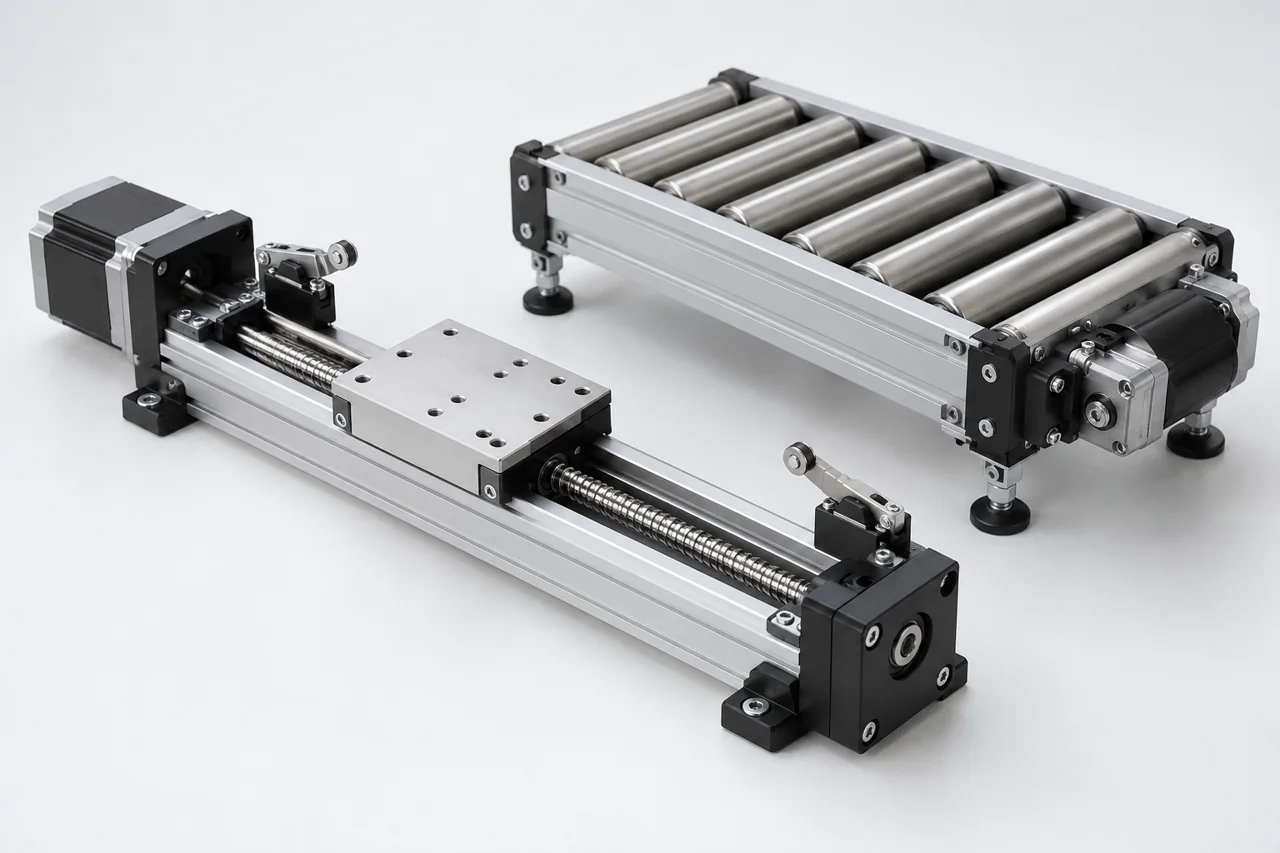
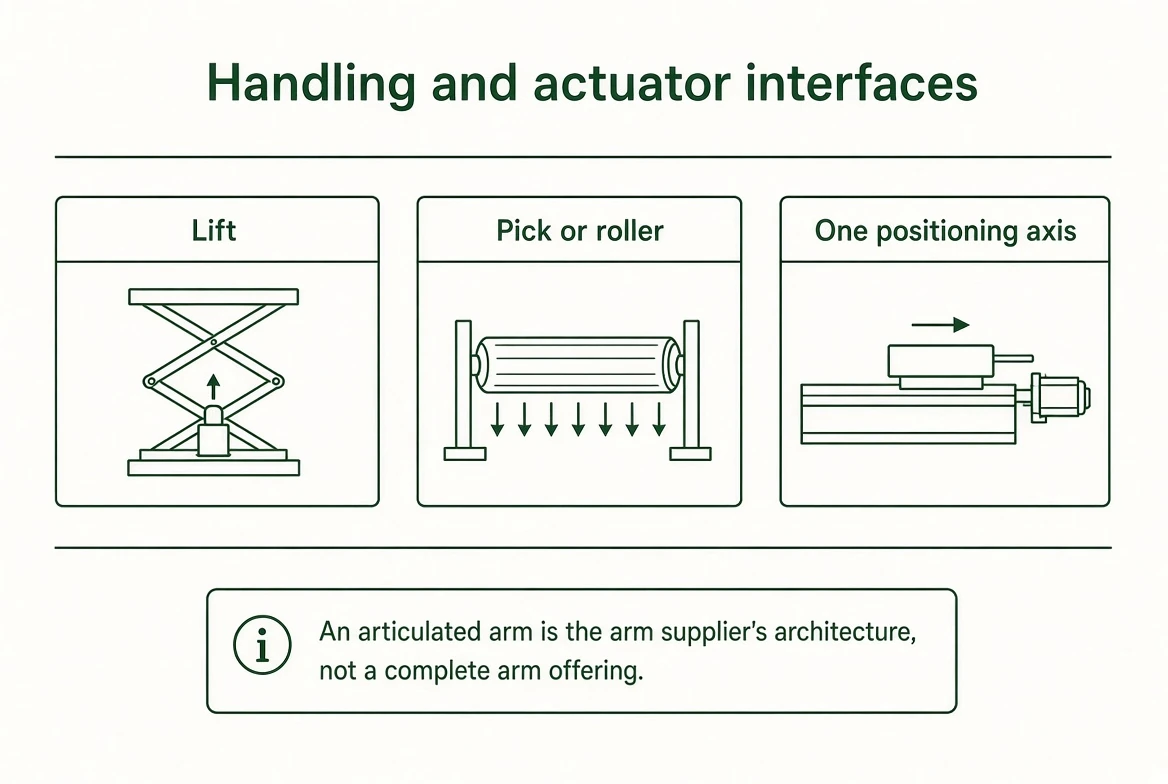
Lifting, picking and positioning have separate actuator interfaces. An articulated arm requires the arm supplier’s axis architecture; this is not a complete robot-arm offering.
FUNCTIONAL INTERFACE GUIDE
Functional breakdown
What makes up this module
Single-axis motor & drive
Single-axis positioning: running torque, speed, holding requirement and pulse/direction or supported command interface.
Open component details ↗Continuous brushless actuator & drive
Wheel, roller or cutter load: torque-speed duty, supply envelope and supported drive command.
Open component details ↗Transmission interfaces
Match motor flange, pilot and shaft; specify ratio, output torque and radial/axial loads.
Open component details ↗Holding brake
Confirm shaft location, holding torque, coil supply, release current and release/engage sequence.
Open component details ↗Home and travel devices
Home reference and travel limits have separate roles; define actuator, contact/output type and controller input.
Open component details ↗Arm-specified power interface
Input range must cover battery sag and charged voltage; define output, load peaks, isolation and heat dissipation.
Open component details ↗Arm-specified power connector
Locked power mating pair: voltage, current, conductor size and who disconnects it during service.
Open component details ↗Define the module interfaces
Actuator type and mechanical load
Travel, speed and peak duration
Drive command and feedback
Holding, limits and equipment stop behavior
PROJECT / MODULE / COMPONENT